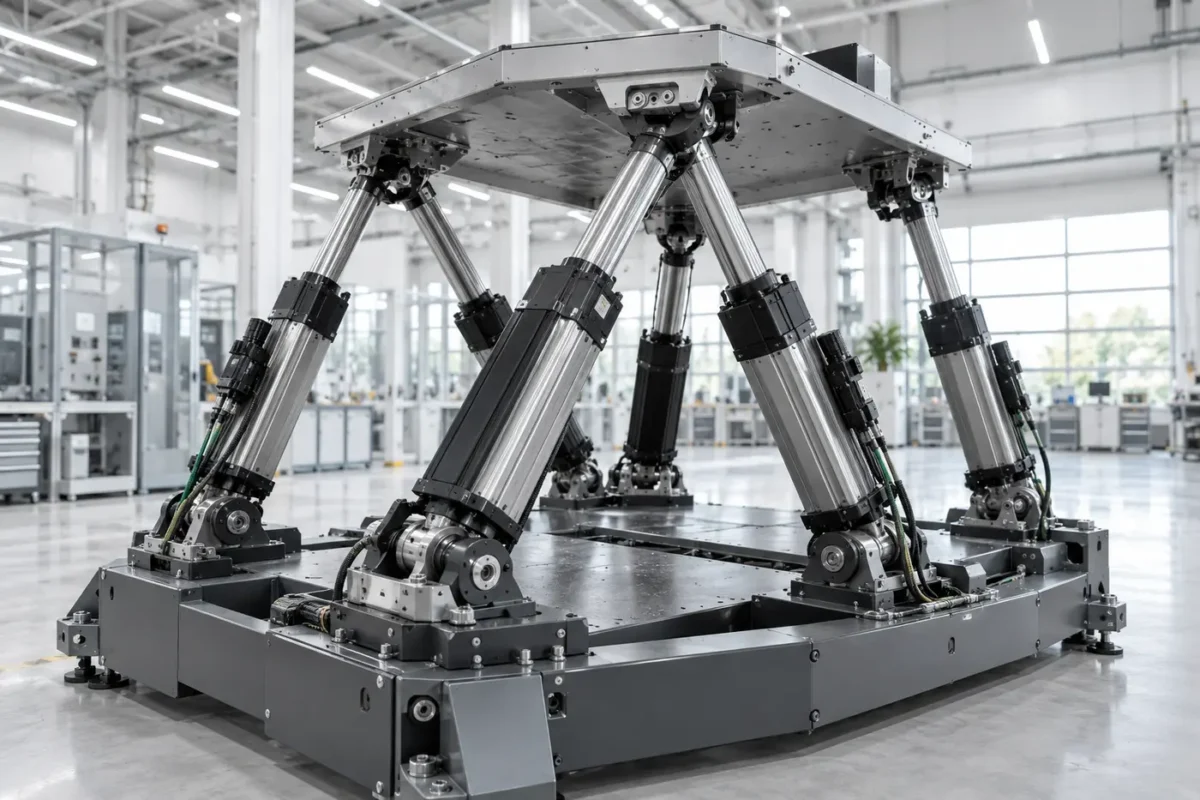
NEFEIT servo electric cylinders and coordinated motion systems can be evaluated for controlled movement in test rigs and simulation platforms. This page describes application engineering inputs rather than verified customer test results.
Test equipment may need repeatable linear displacement, a defined load profile, synchronized axes or a motion platform with a specified payload. The correct architecture depends on the test standard, fixture design and data acquisition needs.
Confirm dynamic load, stroke, velocity, acceleration, cycle duty, fixture stiffness, off-axis forces, controller update rate and synchronization requirements. Define guarding, emergency-stop response and maintenance access with the system integrator.
Specify the test envelope and required axes before sizing any actuator. Model static and transient loads, motion coordination, structural reactions and travel limits. Agree motor and drive compatibility, encoder feedback, controller interface, safety logic and acceptance tests for the whole rig.
NEFEIT has not supplied a customer-approved test report, measured repeatability or platform performance result for this page. Any numerical claim must be confirmed against the selected model and a documented test method before publication.
Review the available servo electric cylinder families and discuss a custom coordinated-motion architecture with NEFEIT. Share payload, degrees of freedom, displacement, frequency, fixture geometry and controller requirements for an engineering review.