Application Solution · Typical Configuration. This engineering example describes an electric-actuator motion platform concept for test and simulation use. It is not a NEFEIT customer project or measured acceptance result.
A laboratory or equipment OEM may need coordinated movement of a test payload to reproduce a prescribed motion profile. The required degrees of freedom, payload geometry and fixture stiffness drive the platform layout.
Define payload mass and center of gravity, displacement and angular range, velocity and acceleration, motion frequency, duty cycle, structural envelope, allowable noise, controller timing and safety limits. The complete rig must be analyzed for each operating pose.
An engineering study compares the actuator load in every pose with continuous and peak ratings, effective stroke and velocity, bearing reactions, screw life and structural deflection. Coordinated axes require compatible drives and deterministic control. NEFEIT must confirm model-specific values before quotation.
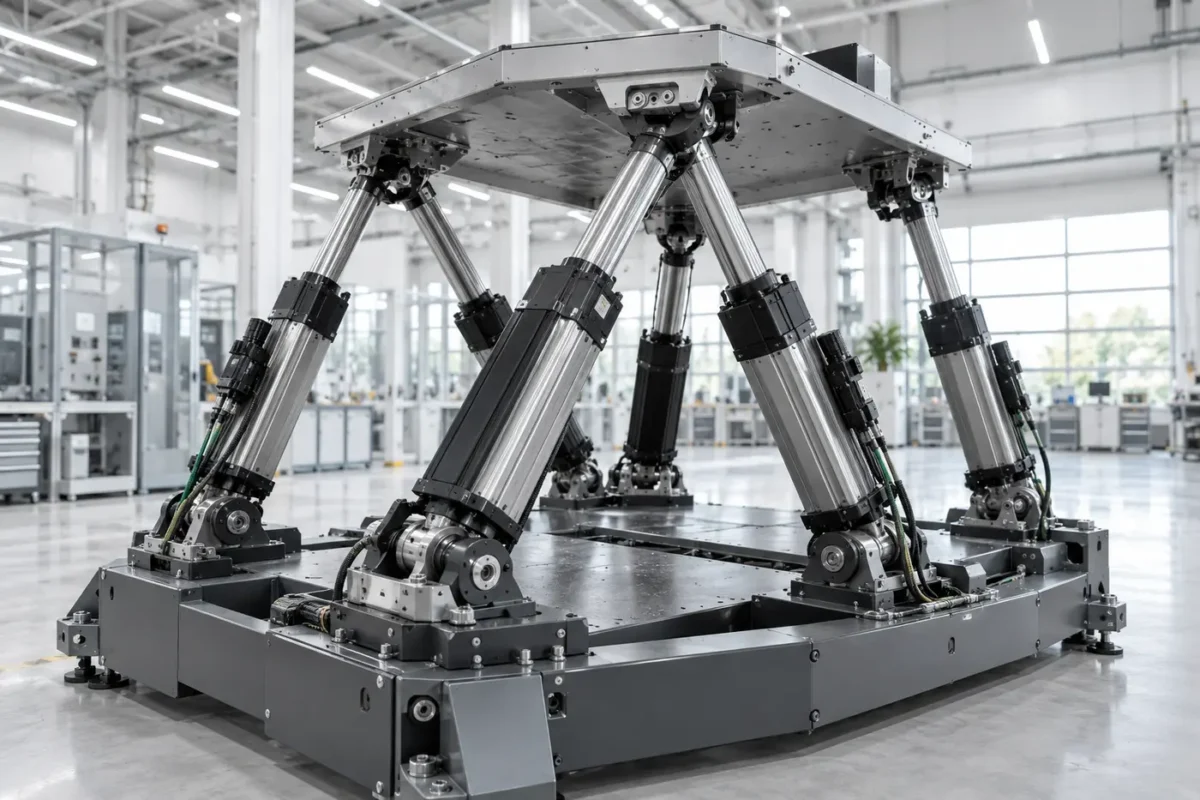
A representative parallel-motion platform uses multiple servo electric actuators between rigid upper and lower frames, jointed mounts, position feedback and a motion controller. The illustrated six-actuator geometry is conceptual; final joint placement, actuator count and kinematics require mechanical design review.
Review joint articulation, load path, cable flex, hard stops, guarding, homing and emergency-stop behavior. Commission the platform with appropriate interlocks and a controlled test plan before applying a full payload or dynamic profile.
No approved customer data, synchronized tracking result, endurance test or platform accuracy is available for this concept. Do not infer performance from the illustration. Publish quantified results only against a documented build and test protocol.
Review NEFEIT servo electric cylinders as potential linear axes. Send payload, center of gravity, axis requirements, stroke and frequency profile, integration drawing and controller preference for an engineering assessment.